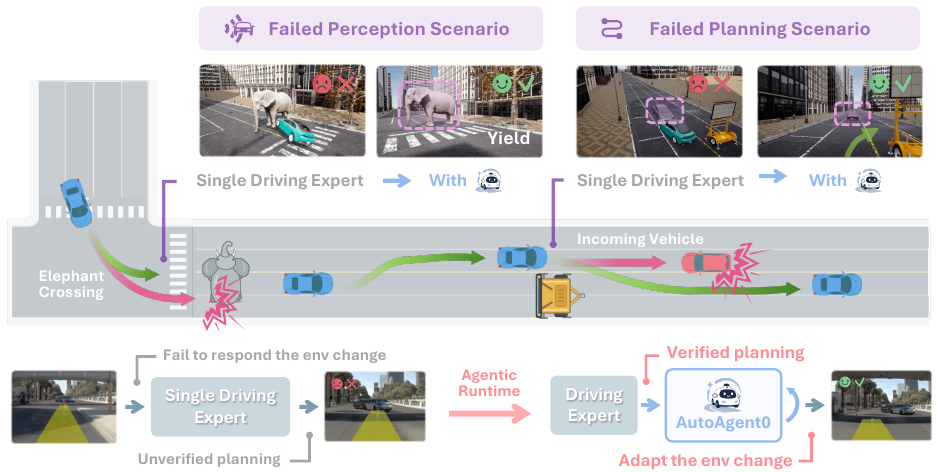
AutoAgent0: An Agentic Runtime for Safe Closed-Loop Driving
Preprint, 2026
Runtime supervision, trajectory checks, and feedback-driven recovery for closed-loop driving.
I am a Ph.D. student in the UCLA Mobility Lab at the University of California, Los Angeles, advised by Prof. Jiaqi Ma.
Previously, I received my M.S. in Computer Science from UMass Amherst and worked closely with Prof. Ming-Hsuan Yang at UC Merced. I received my B.S. in Artificial Intelligence from the Chu Kochen Honors College and Turing Class at Zhejiang University, advised by Prof. Zhou Zhao.
My research focuses on spatial intelligence for embodied AI. I study how agents understand and act in 3D environments from incomplete observations, and how we can efficiently construct and edit the worlds they inhabit. My work follows two connected directions:
Selected and related publications below. * denotes equal contribution unless otherwise noted in the paper.
From imagining unseen views and maintaining spatial memory to actively gathering evidence and recovering from execution errors.
Preprint, 2026
Runtime supervision, trajectory checks, and feedback-driven recovery for closed-loop driving.
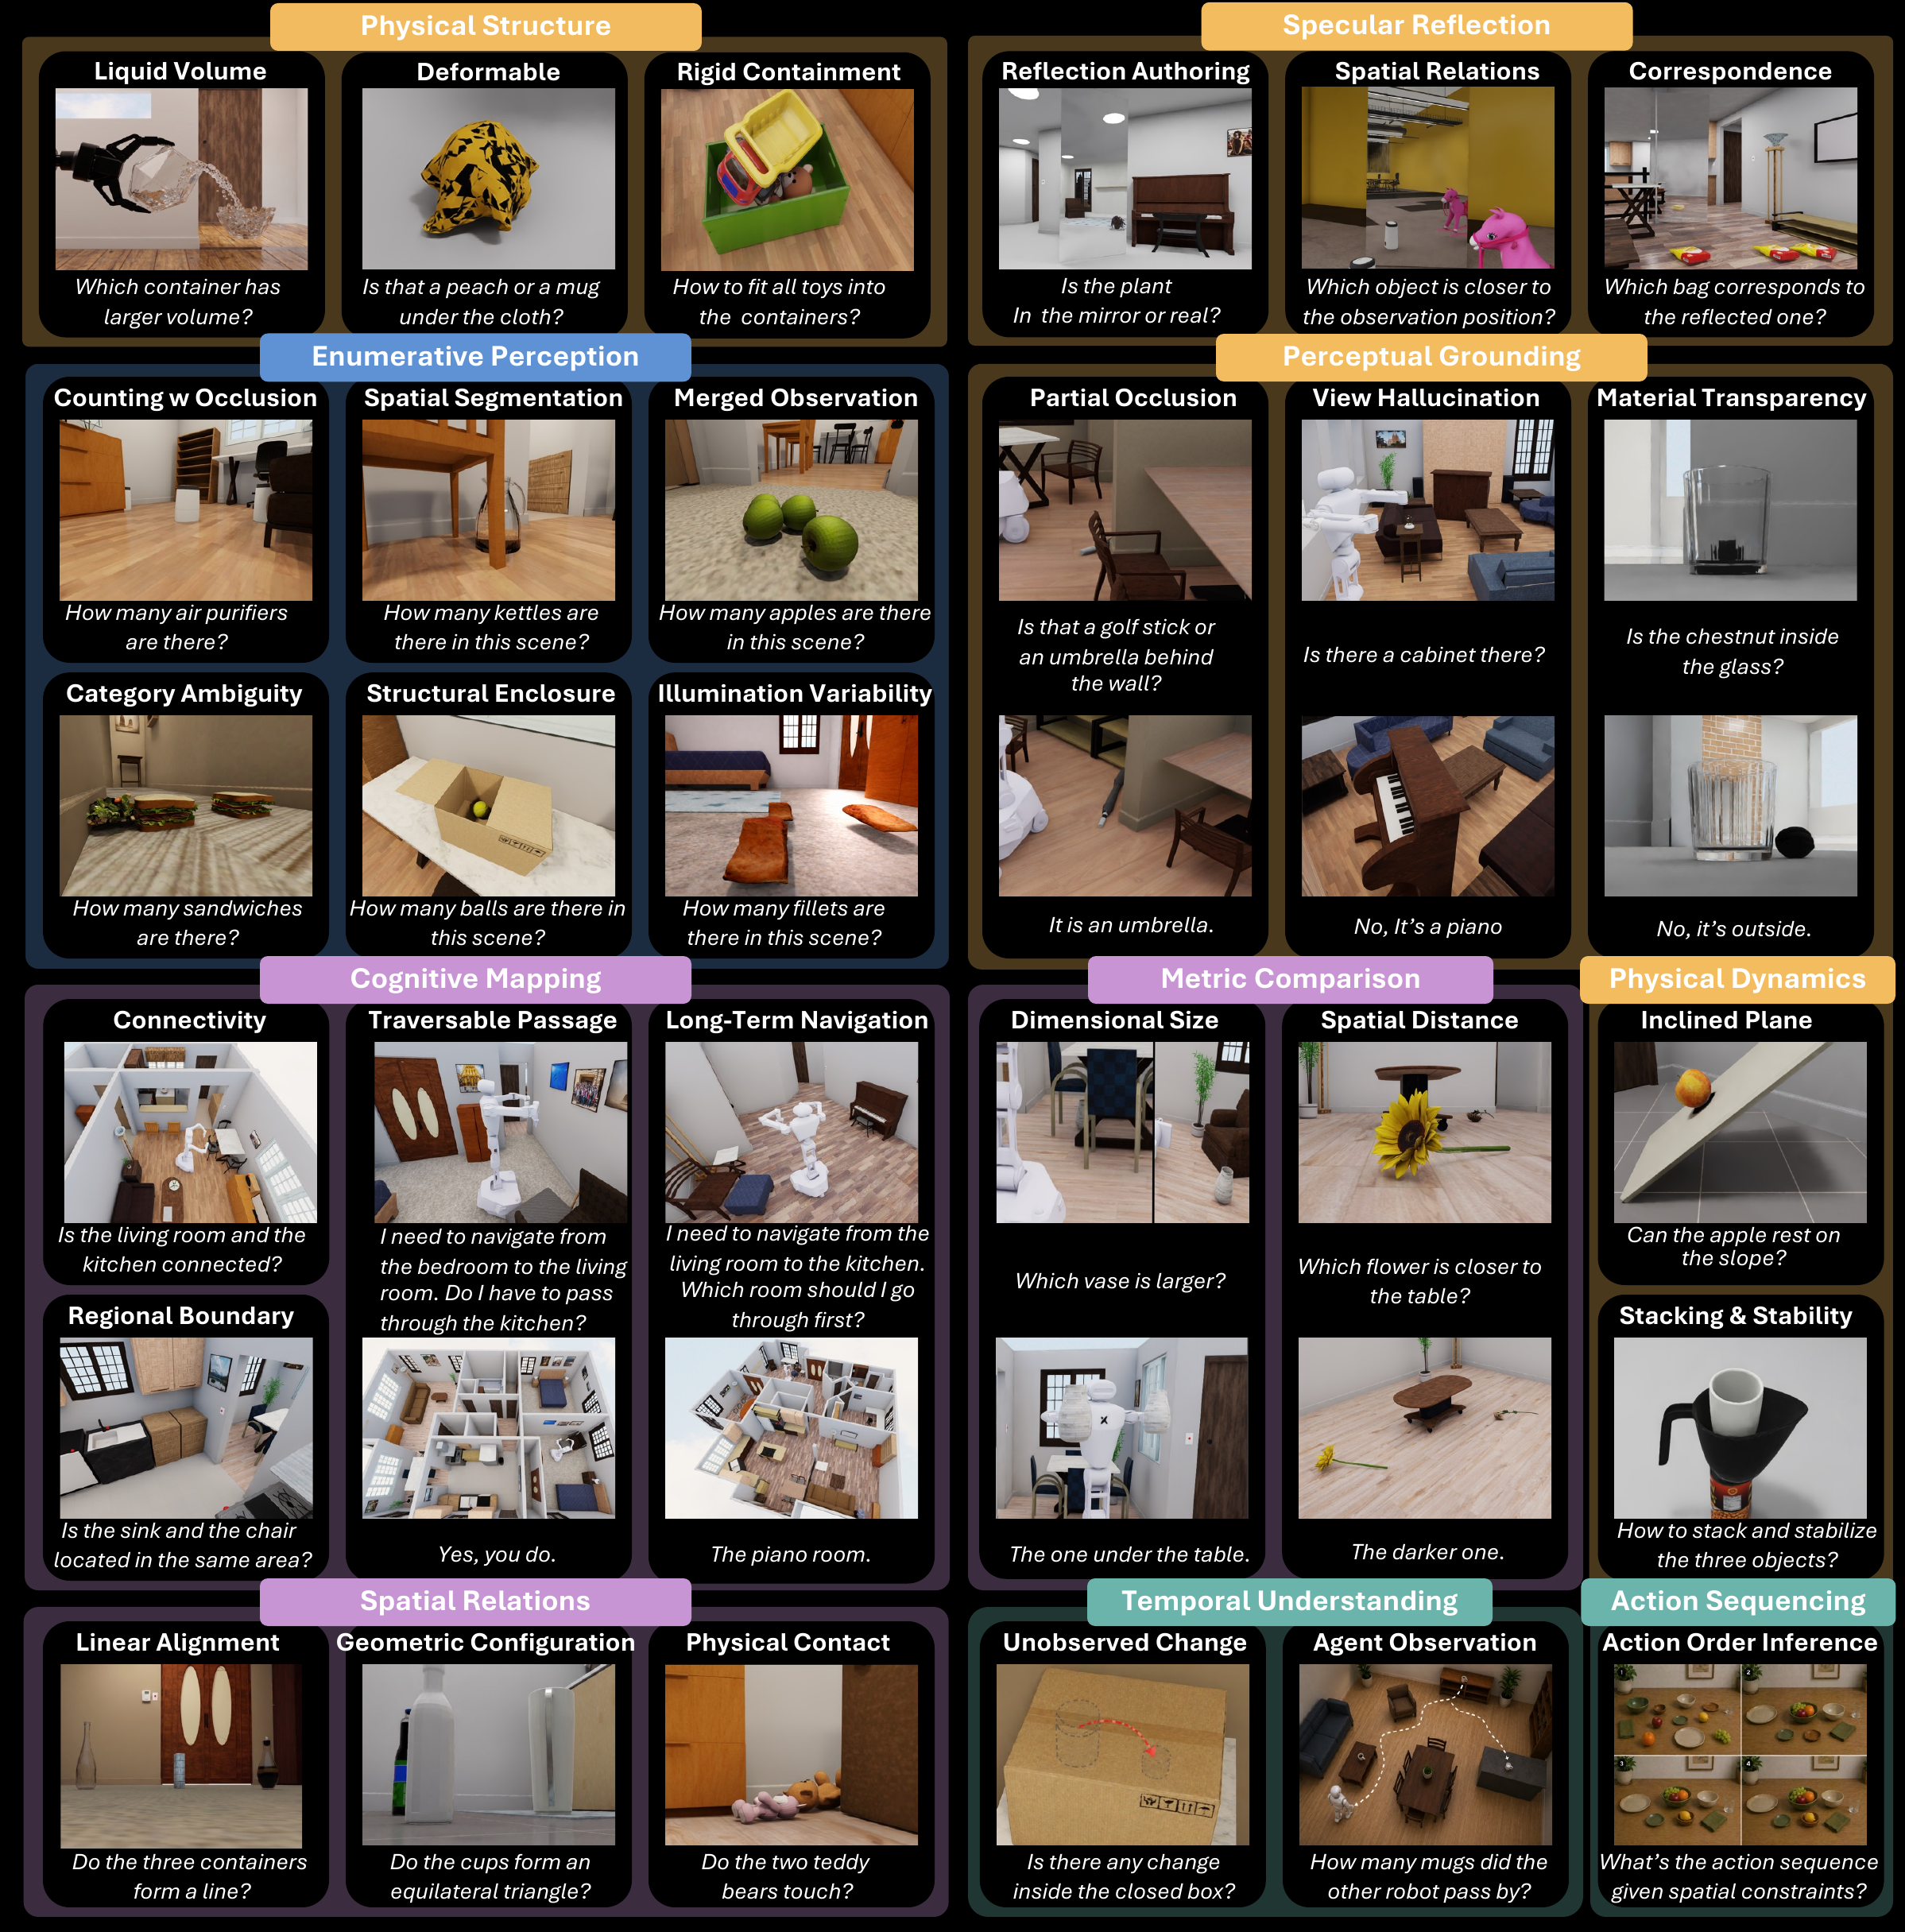
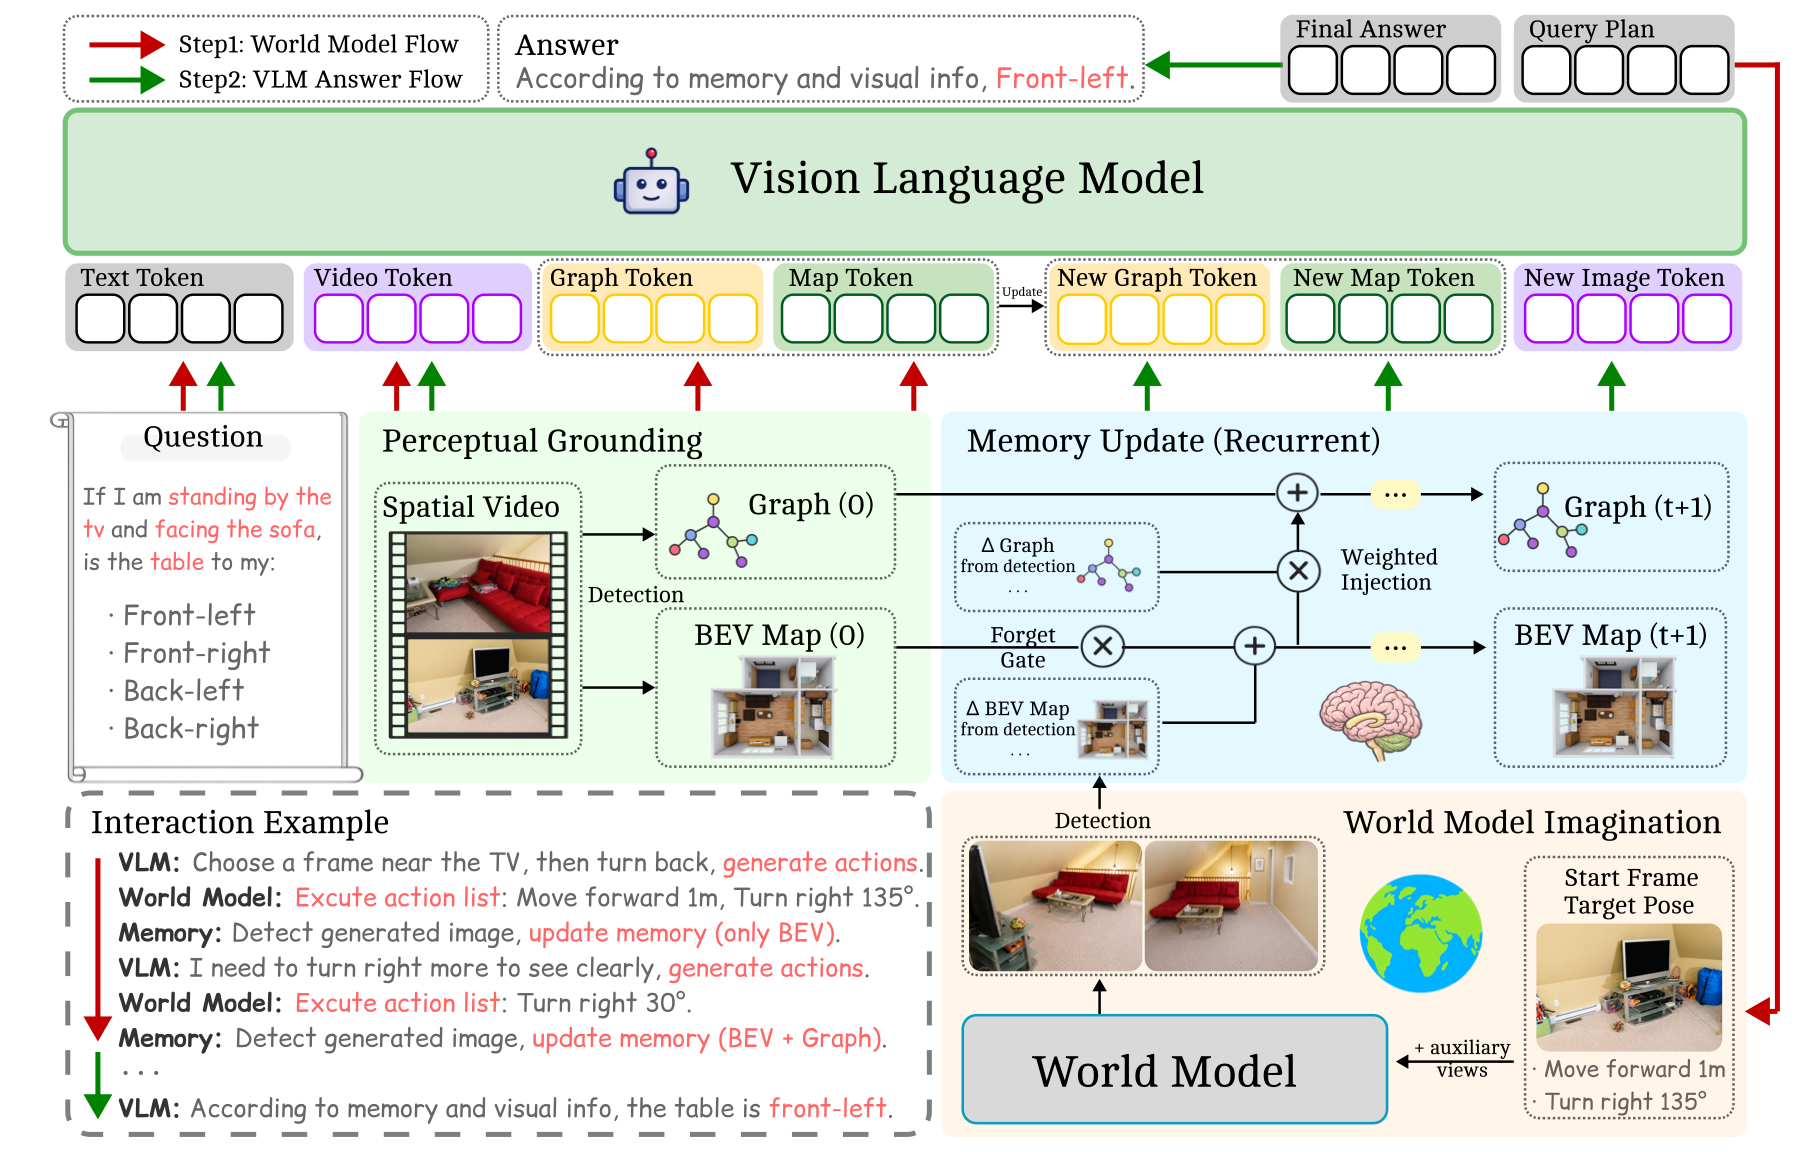
Preprint, 2026
Combining structured spatial memory with imagined views to reason across viewpoints and over time.
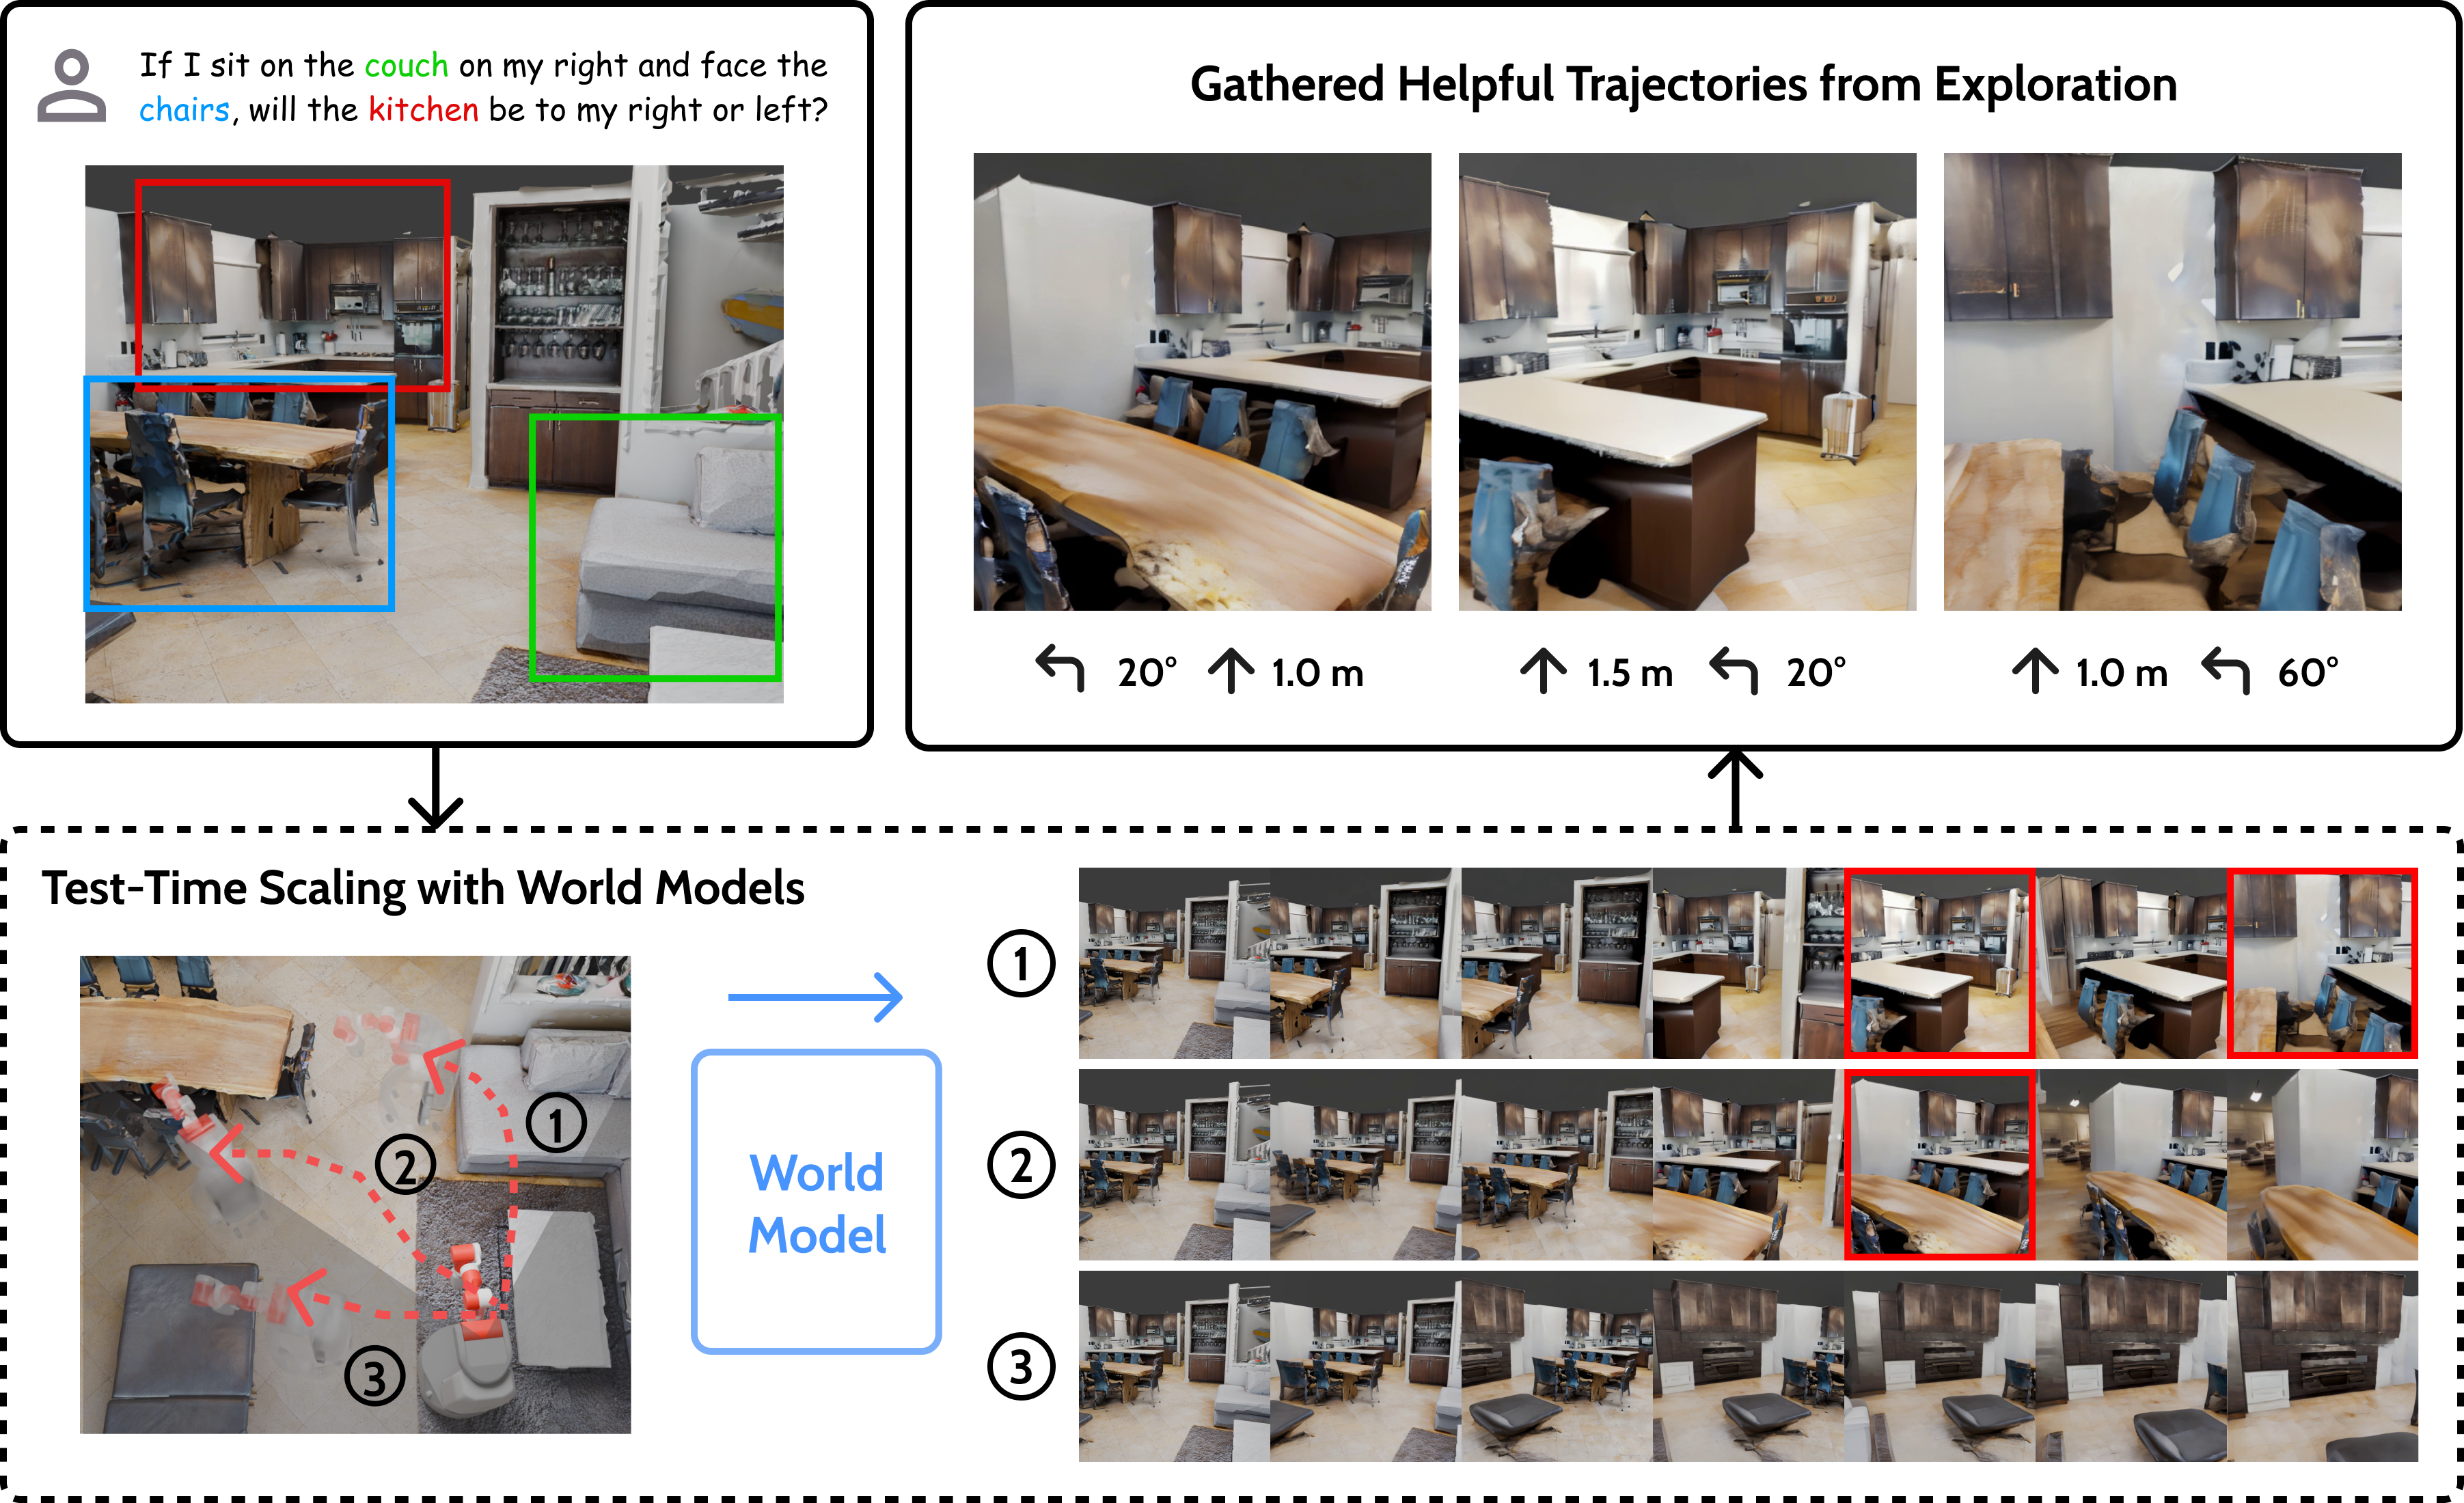
NeurIPS 2025
Using controllable world models to explore new viewpoints and improve spatial reasoning at test time.
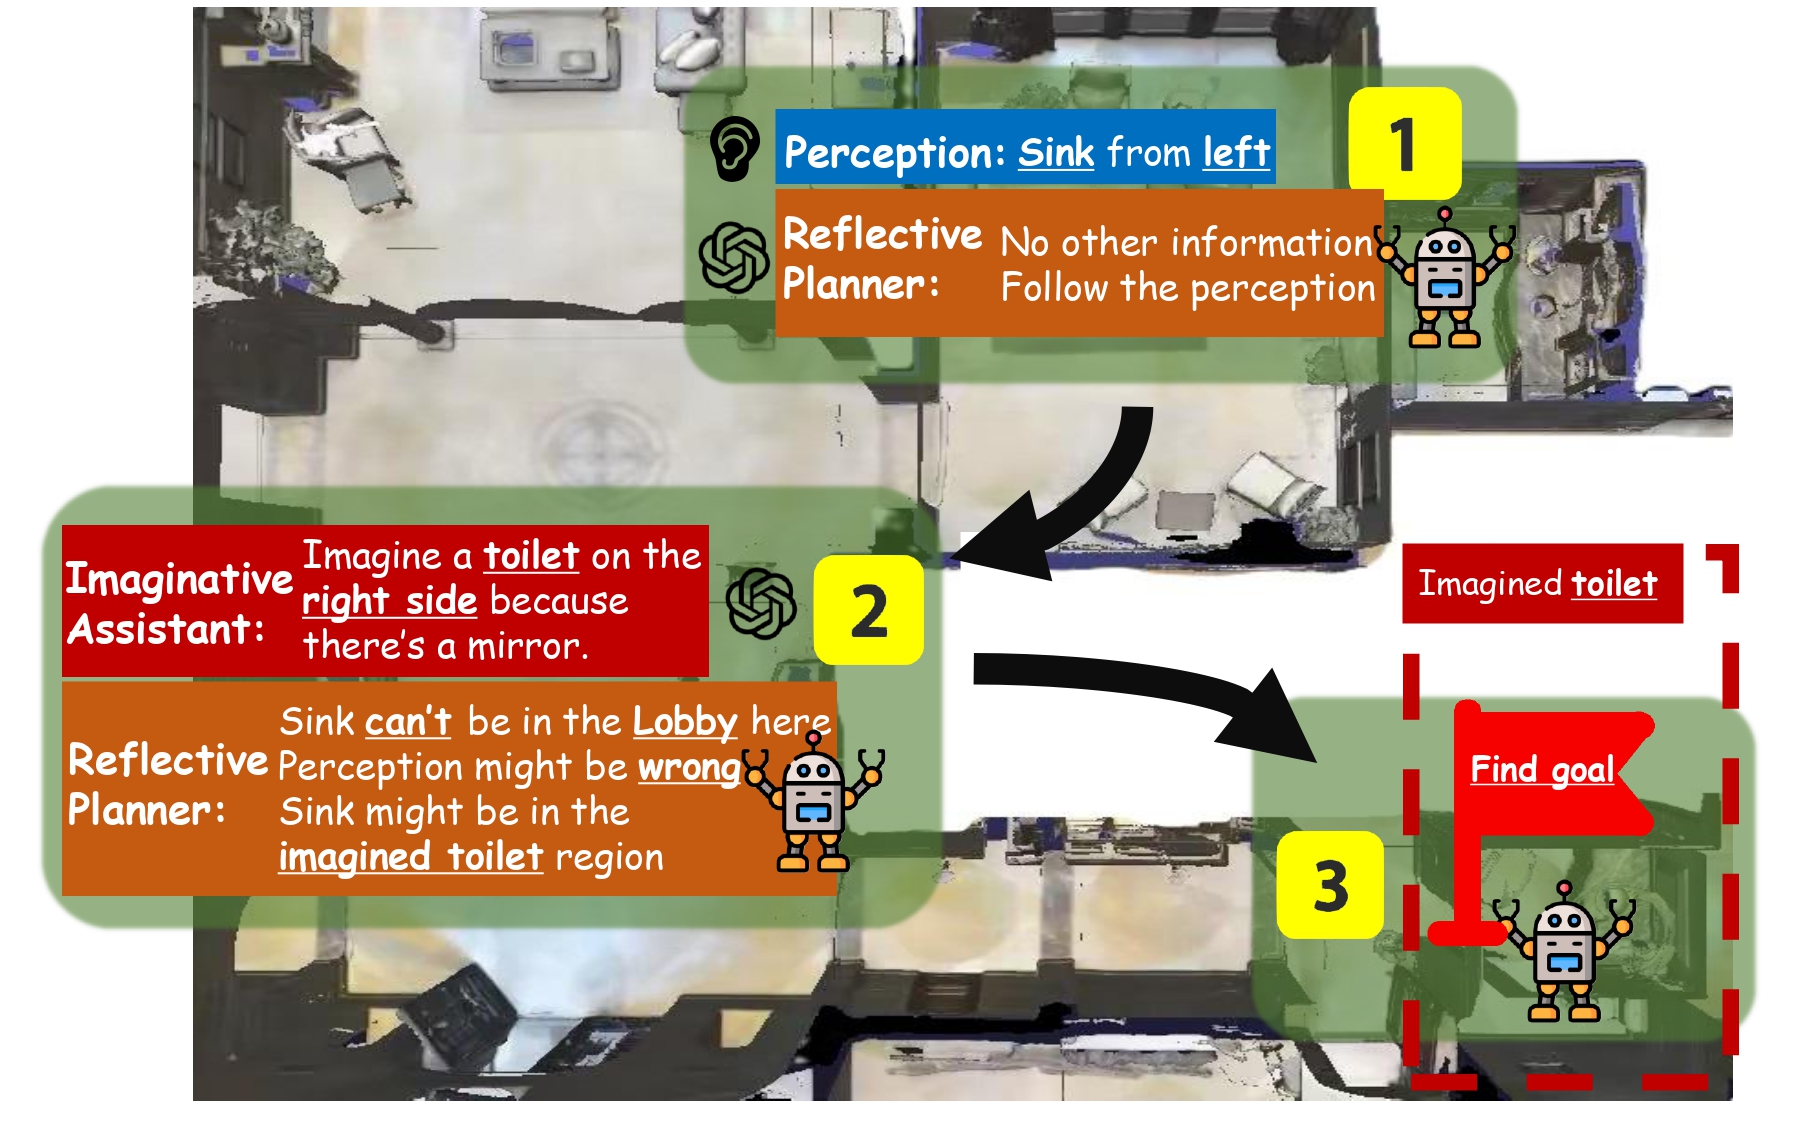
CVPR 2024
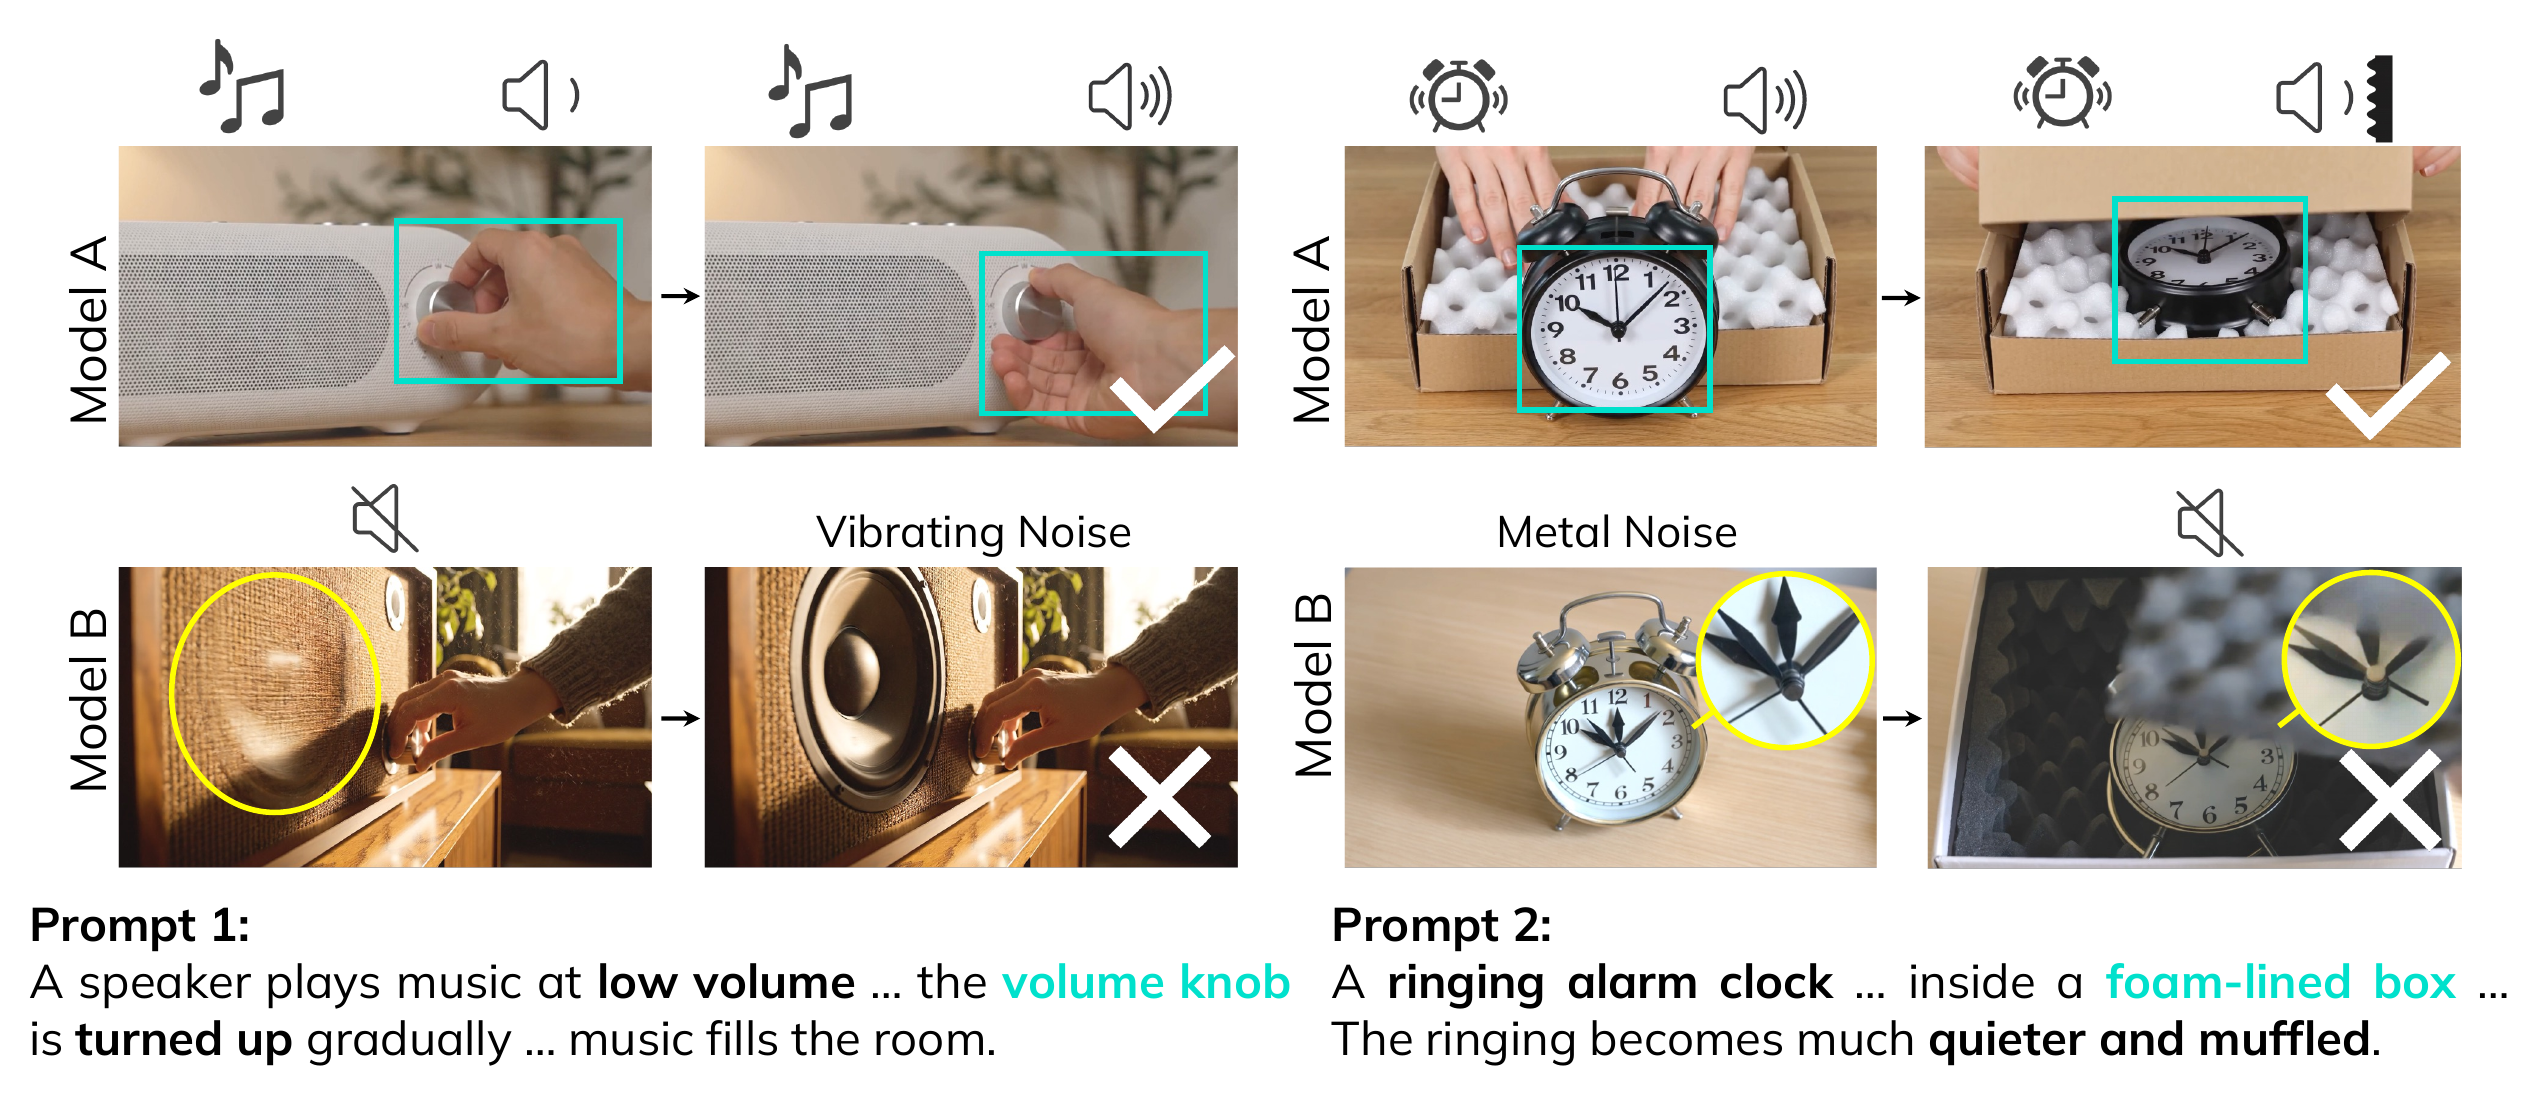
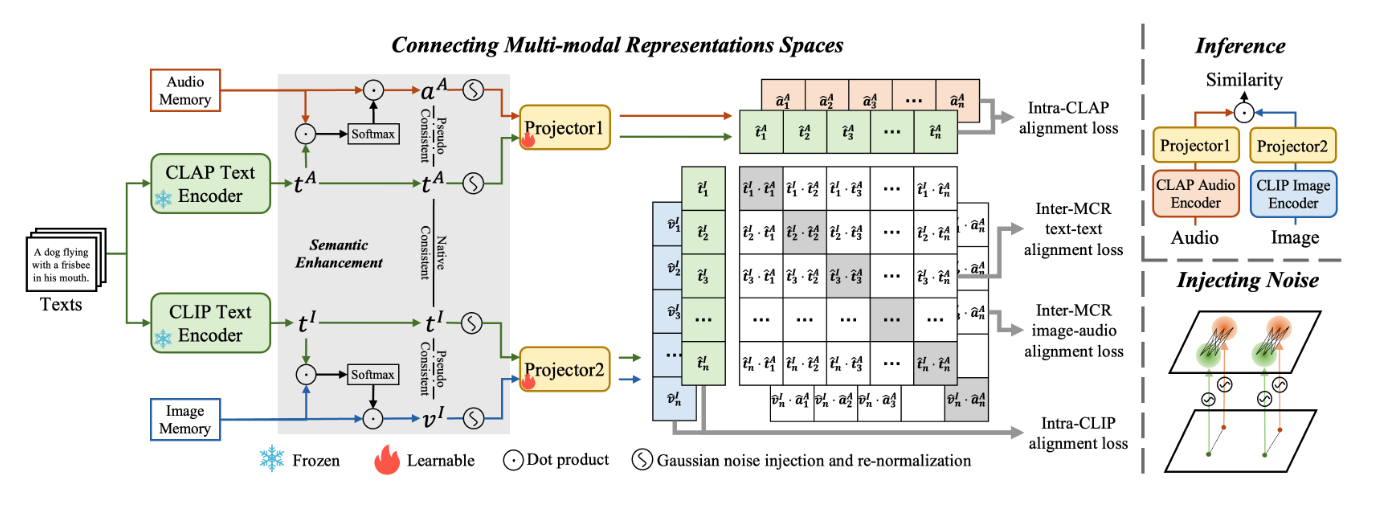
Reflecting on uncertain audio-visual cues and adapting exploration for zero-shot navigation.
Generating and editing coherent 3D scenes, and extending scene construction to interactive worlds with humans and robots.
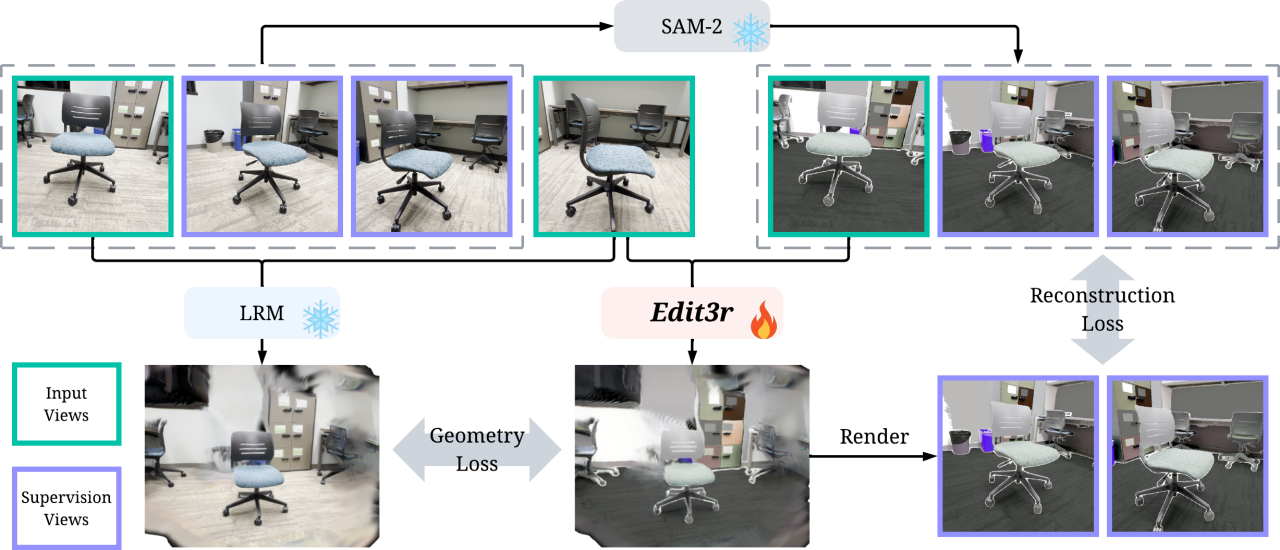
ECCV 2026 · Oral
Fast, instruction-driven 3D scene editing from sparse unposed images, with consistent novel views.
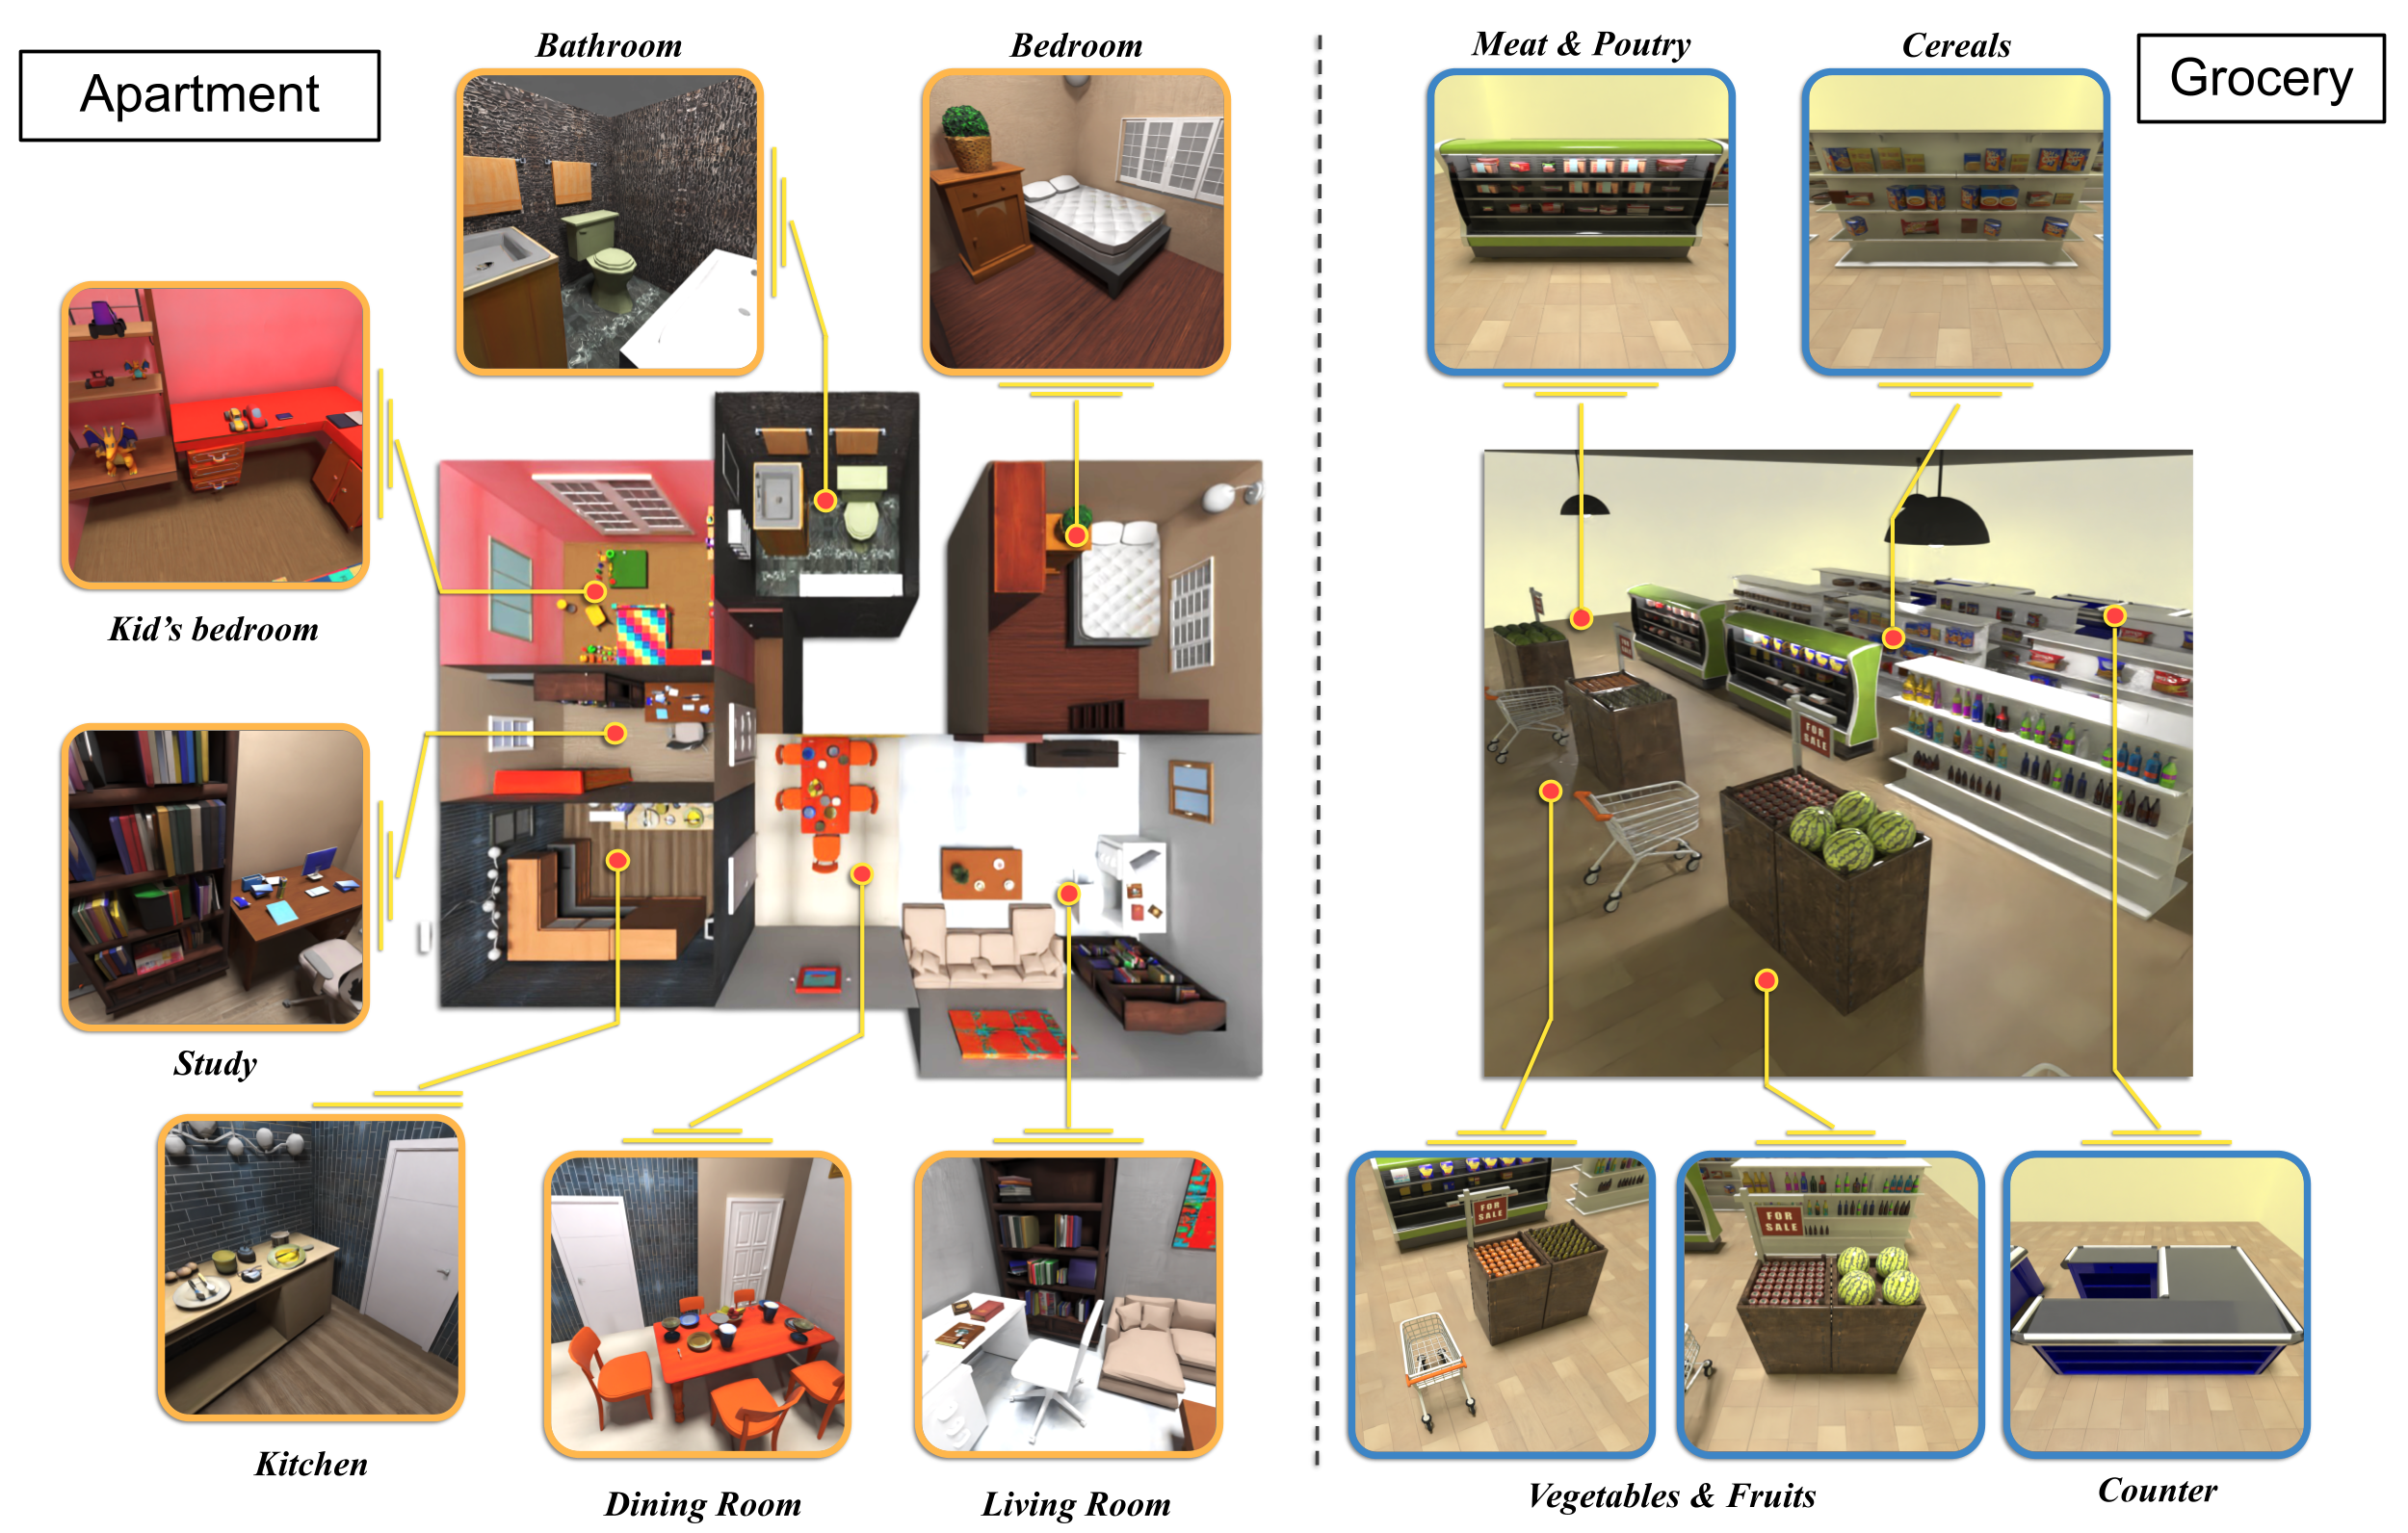
NeurIPS 2024
Turning 2D generative priors into rich, interactive 3D environments through hierarchical inpainting.
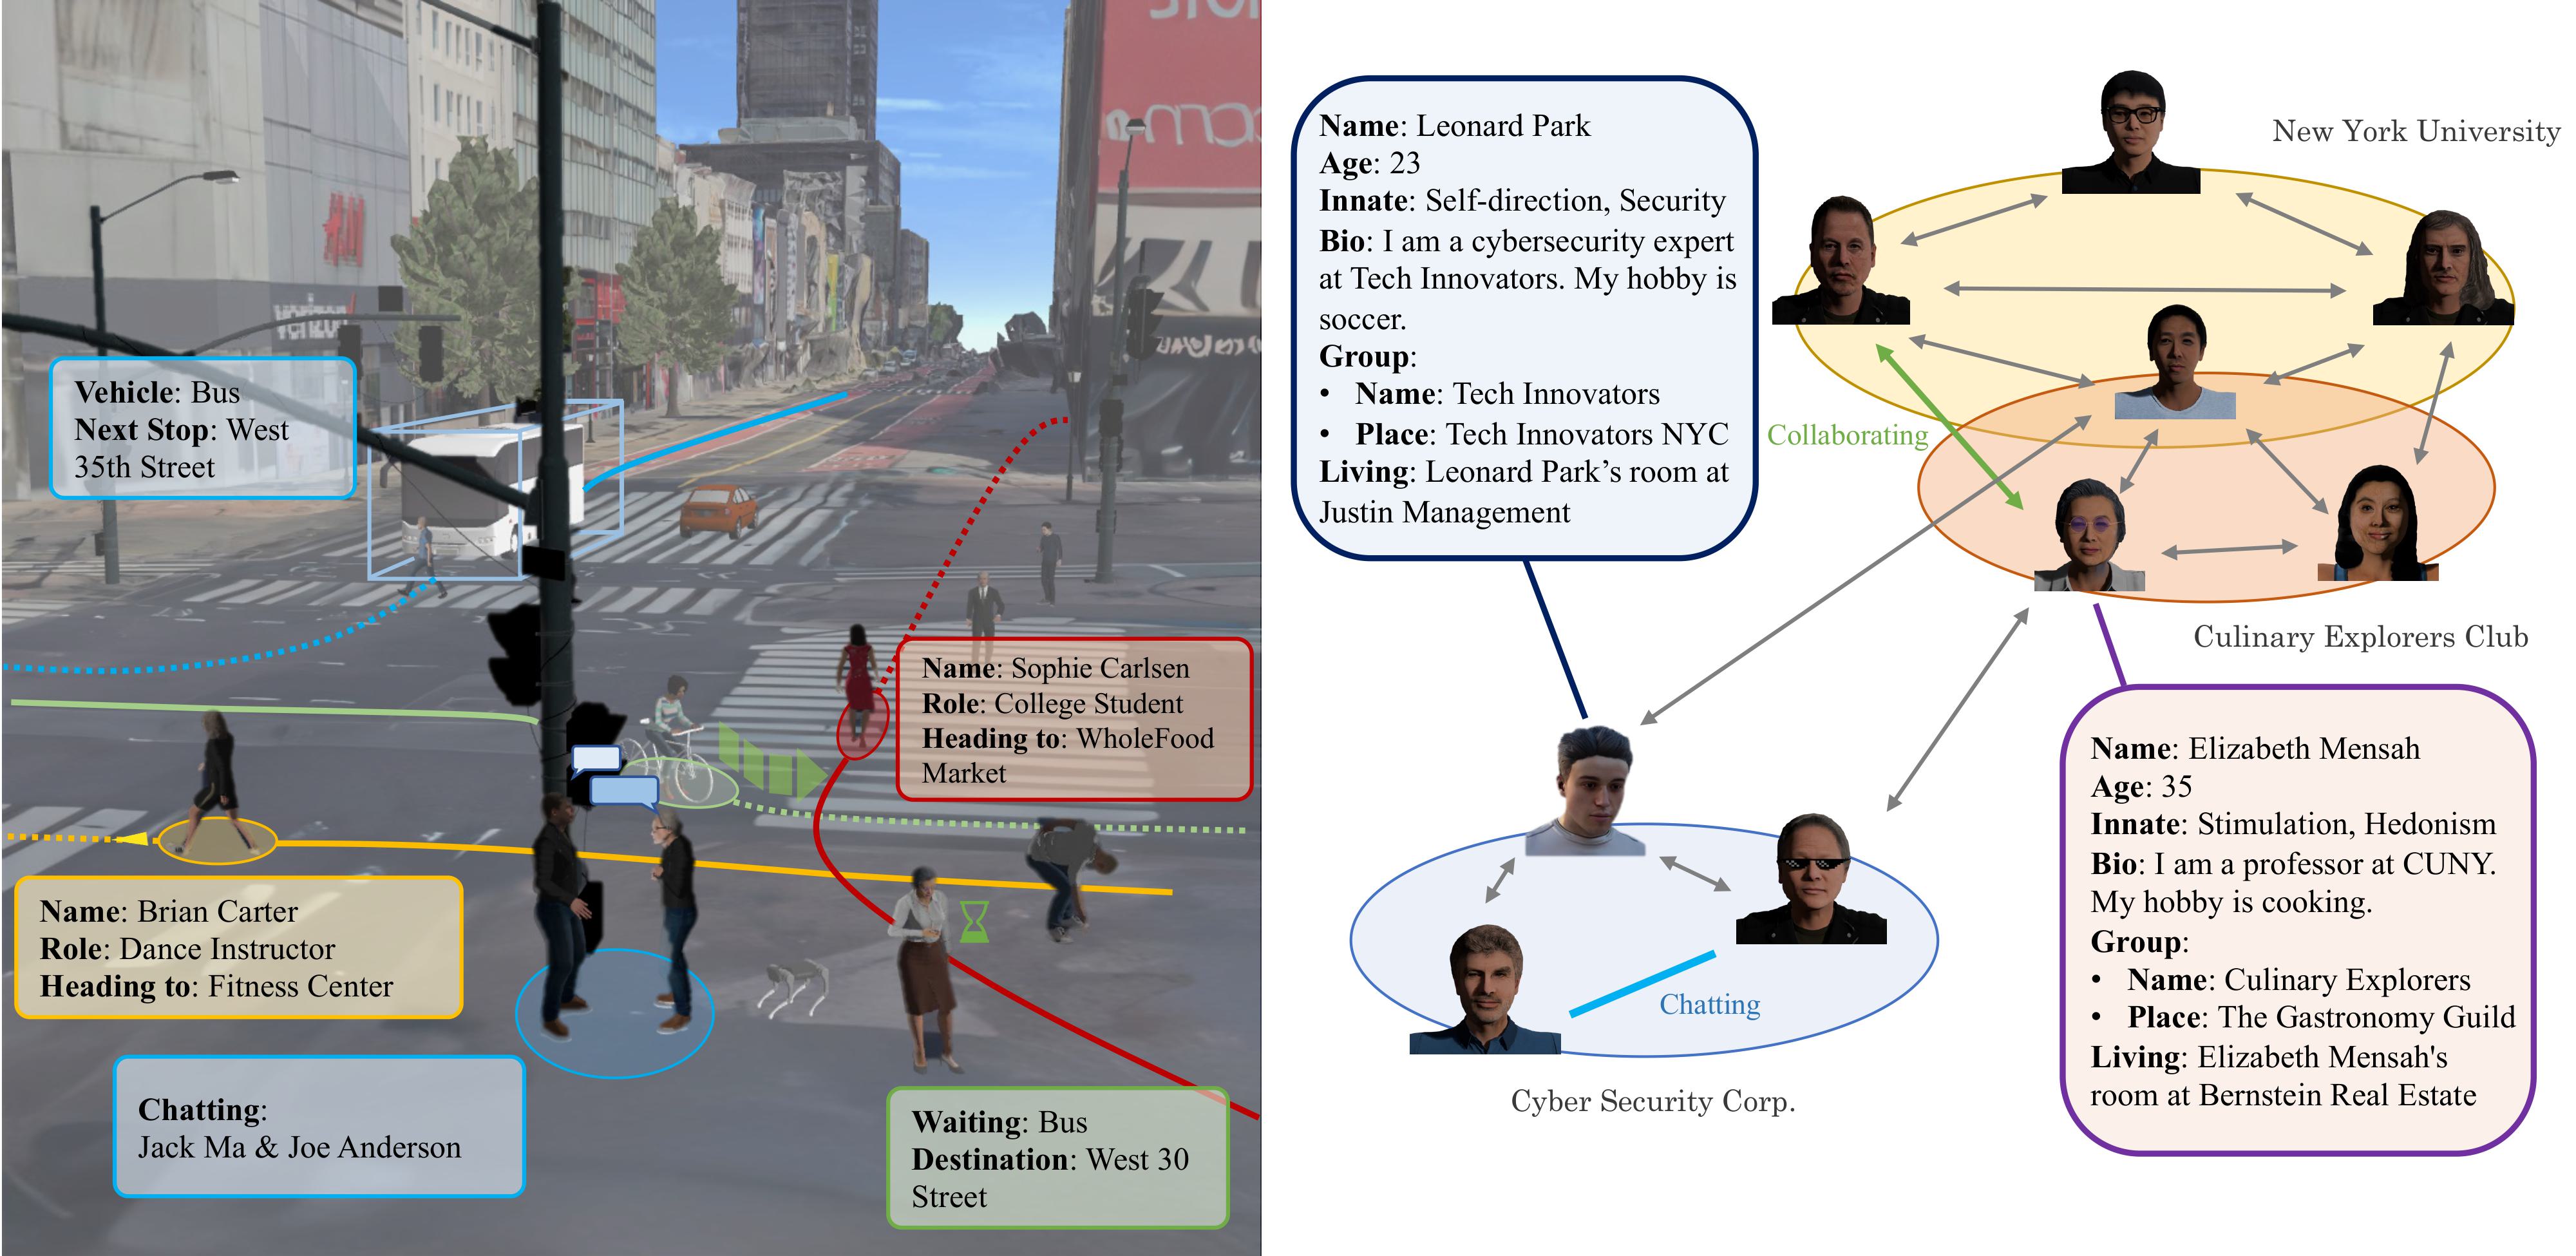
ICLR 2026
Scaling scene construction to open worlds with humans, robots, and socially grounded agent communities.
Multi-modal scene representation and navigation in Habitat; Advisor: Nirav Savaliya.
Led Edit3r on instant 3D scene editing from sparse, unposed images; Advisor: Ming-Hsuan Yang.
MindJourney: Test-time scaling with controllable world models for 3D spatial reasoning; Advisor: Jianwei Yang.
ARCHITECT and RILA for 3D scene generation and audio-visual navigation;
Mobility Lab; advised by Jiaqi Ma.
College of Information and Computer Sciences (GPA: 4.00/4.00).
Turing Class, Chu Kochen Honors College; GPA: 3.75/4.00 (Major GPA 3.96/4.00).
Conference Reviewer: NeurIPS 2025, NeurIPS 2026, CVPR 2026, ICLR 2027
Journal Reviewer: IEEE Transactions on Pattern Analysis and Machine Intelligence (TPAMI), IEEE Transactions on Automation Science and Engineering (TASE), IEEE Open Journal of Intelligent Transportation Systems (OJ-ITS)
Feel free to reach out at jiagengliu02@g.ucla.edu.
Calendar shown in Pacific Time.